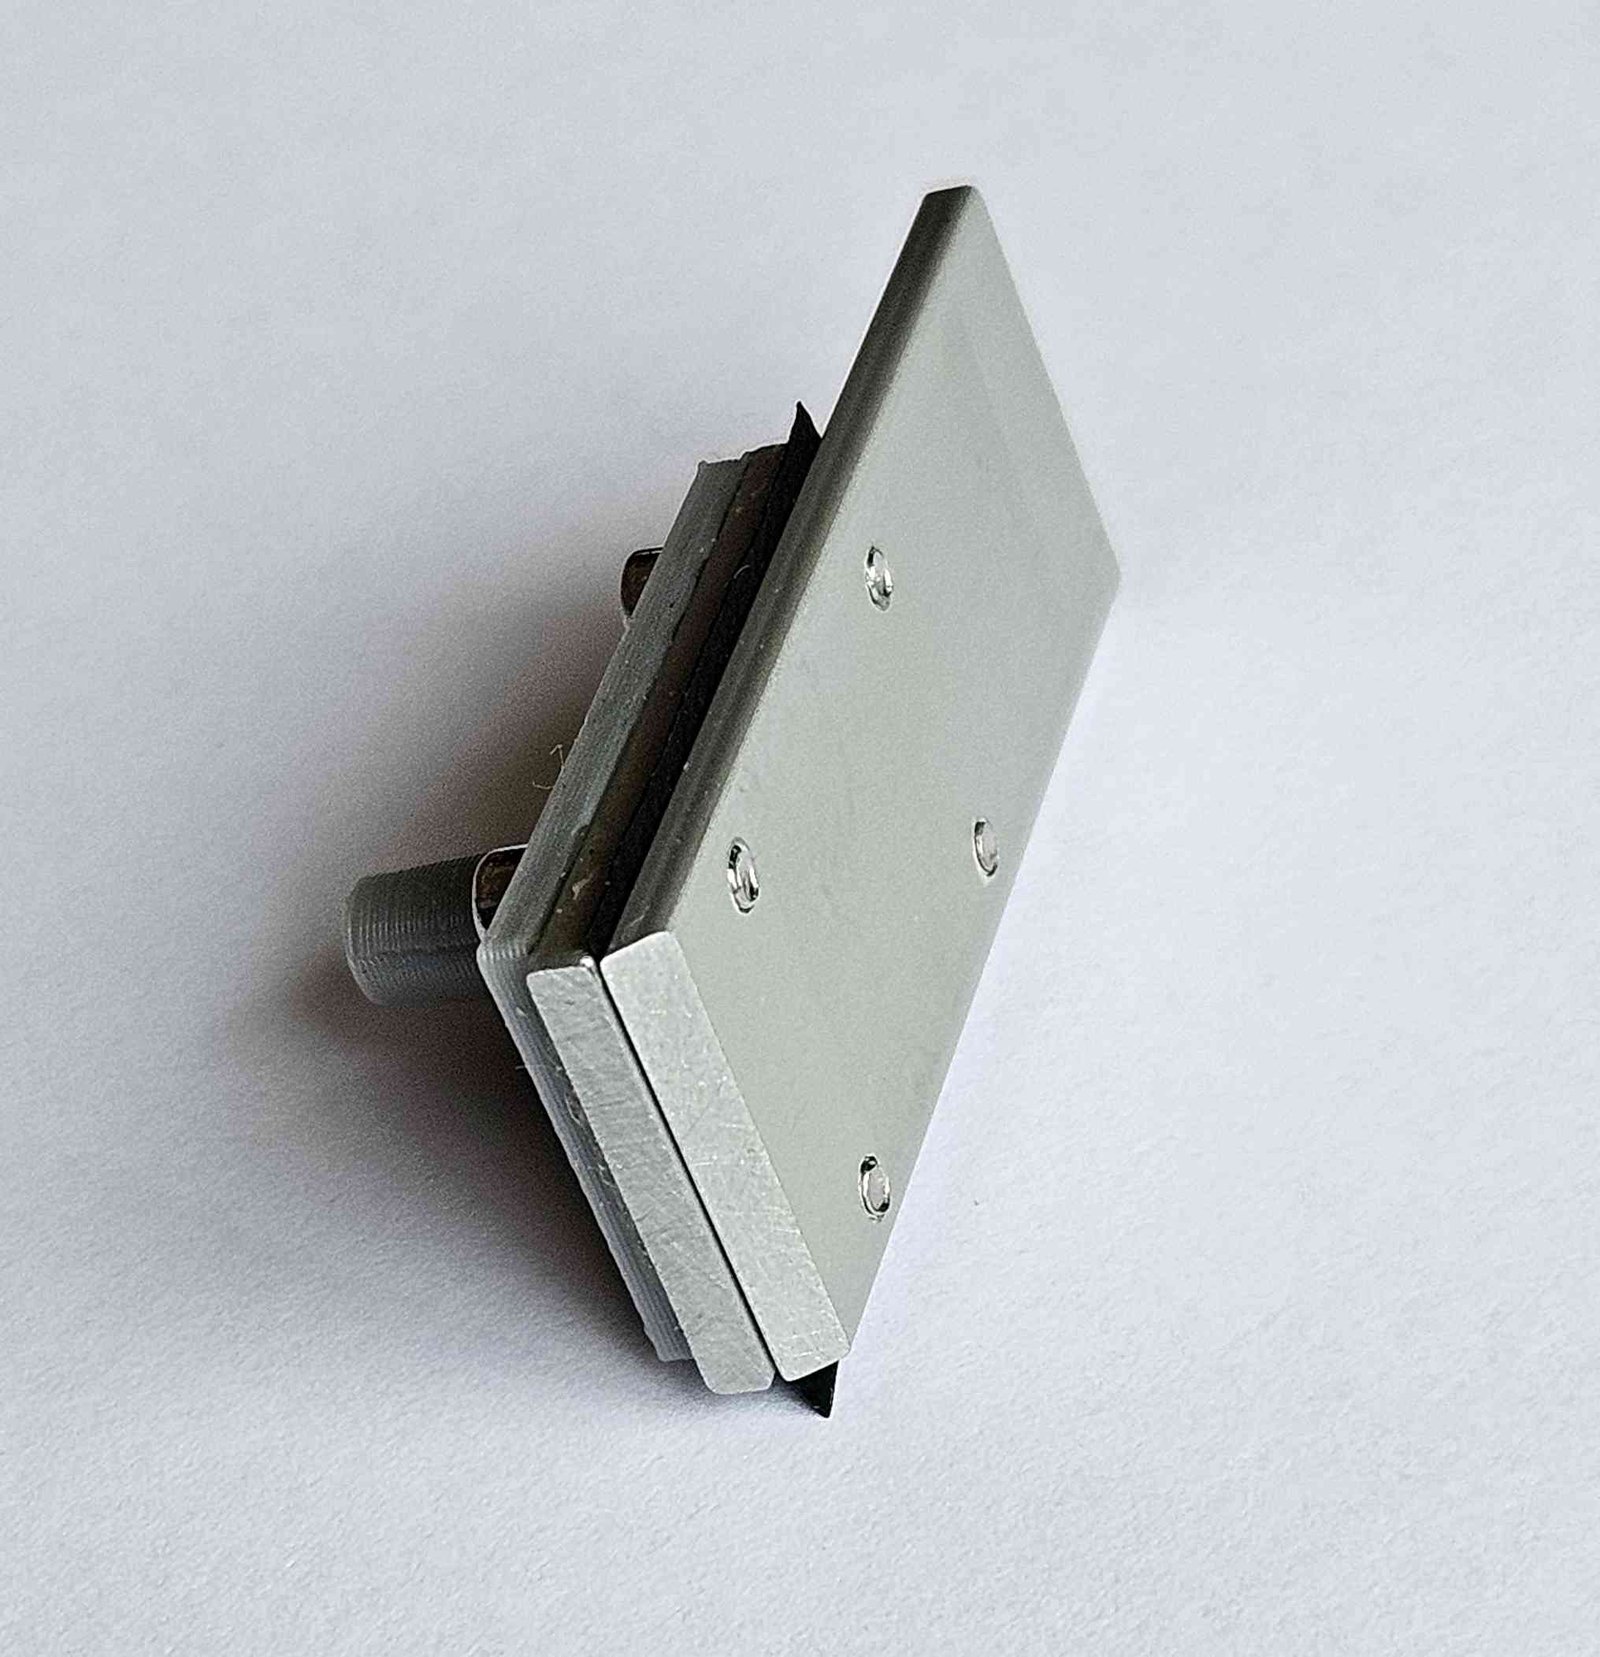
Investigated the feasibility of robotic handling of optical fiber in automated fiber-processing workflows, where operators typically transfer fibers manually between specialized equipment, including fusion splicers, cleavers, ultrasonic cleaners, and coating strippers.
Developed a 3D-printed robotic arm for evaluating end-effector concepts and demonstrated a vacuum-based pickup mechanism for 250 µm coated optical fiber. Designed a MOSFET switching array for microcontroller-based control of motors and solenoid valves. Also developed and demonstrated a lever mechanism for opening magnetic fiber clamps.
The project established key building blocks for robotic fiber transfer, combining mechanical prototyping, custom electronics, embedded control, and experimental validation.